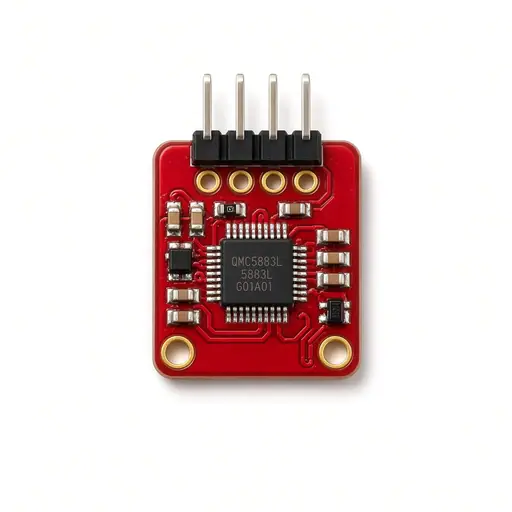
MPU-6050 6-DOF Accel + Gyro
by InvenSense / clone
SKU: PSA-CMP-MPU6050
No reviews yetTypical India street price
₹80–₹160
IMU for tilt, shake, and self-balancing robots.
Interface: I2C
I2C MPU6050 for tilt and gesture projects — pair with OLED HUD.
SDA/SCL on I2C bus; address 0x68 typical.
Open PSA LabGet notified if we start selling this part
Concept
MPU-6050 is a 6-DOF IMU: a 3-axis accelerometer plus a 3-axis gyroscope on one I2C chip — the heart of tilt, shake, and self-balancing projects.
A little theory
MEMS capacitive combs sense acceleration (including gravity) and angular rate. Accel ranges typically ±2 to ±16 g; gyro in °/s. Raw counts need scale factors from the datasheet. Gyro integrates to angle but drifts; accel is noisy when moving. A complementary or Madgwick filter fuses both for a stable pitch/roll estimate. Address 0x68 when AD0 is low (0x69 when high). In the classroom, treat MPU-6050 6-DOF Accel + Gyro as a intermediate part using I2C. Typical India street price is about ₹80–₹160. Always verify voltage and pin labels on your exact module — silk screens vary across clones. Start with a datasheet or trusted learn guide, power the part correctly, share GND with the MCU, and test with a simple blink/read sketch before building the full project. Measure voltages with a multimeter when something fails, and keep actuator current off the MCU regulator.
How it works in a project
Wire VCC/GND/SCL/SDA. Use Adafruit MPU6050 or Jeff Rowberg’s DMP examples. Calibrate offsets at rest on a level desk before balancing robots.
Classroom & project use
- Gesture steering
- Self-balancing bot
- Activity / fall detect
- Camera gimbal tilt
Buying in India
Precautions
- Mount firmly — vibration aliases as acceleration
- Calibrate offsets at rest
- 3.3 V logic on bare chips; modules often 5 V tolerant
Specifications
| Bus | I2C 0x68/0x69 |
| Accel | 3-axis |
| Gyro | 3-axis |
| Package | GY-521 common |
| Category | Sensors |
| Difficulty | Intermediate |
| Voltage | 3.3–5V (module 5V-tolerant) |
| Interface | I2C |
Pinout
VCC | GND | SCL | SDA | XDA | XCL | AD0 | INT